 Crypto.
 О нас
 Passport
 Conference call
 send money
 Условия использования
 Конфиденциальность
 Sierra market
Comprehensive Algorithmic Frameworks And Kinematic Performance Metrics In Autonomous Crop Harvesting
A detailed engineering evaluation of modern precision agriculture demonstrates that the Crop Harvesting Robot Market Analysis is anchored by advanced inverse kinematics, high-density sensor fusion, and real-time path planning in chaotic, unstructured natural environments. Unlike factory automation settings where industrial robotic arms interact with identical parts in rigidly controlled, static environments, an agricultural harvesting robot must operate amidst continuous uncertainty. Wind blows branches across visual sensors, ambient illumination shifts unpredictably, and target fruits are frequently occluded by leaves, trellises, or adjacent unripened clusters. To perform reliable harvesting routines, robots utilize complex motion-planning algorithms, such as rapidly exploring random trees (RRT*) and deep reinforcement learning (DRL) policies. These algorithms compute collision-free trajectories that weave flexible arms through dense foliage, touch down precisely on the target pedicel, and detach the fruit cleanly without shaking adjacent unripe produce loose.
The architectural reliability of sensor-fusion networks within harvesting machinery is paramount to maintaining high picking accuracy and avoiding expensive mechanical collisions. Agricultural mobile platforms fuse telemetry from 3D time-of-flight (ToF) cameras, stereoscopic vision modules, ultrasonic proximity sensors, and LiDAR arrays using extended Kalman filters. This layered perception model creates a real-time, three-dimensional point-cloud map of the picking zone, allowing the system to differentiate structural branches, structural support wires, irrigation lines, and crop foliage. If a sudden gust of wind moves an apple branch mid-approach, the robot’s closed-loop visual-servoing system updates its trajectory in real time, recalculating kinematic solutions dynamically rather than executing a blind, pre-programmed stroke. This closed-loop agility prevents costly damage to valuable perennial orchard vines and protects the robot’s high-precision mechanical linkages from destructive high-velocity impacts.
From an algorithmic standpoint, the fruit-detachment mechanism represents one of the most critical engineering challenges in the agricultural robotics domain. Simply pulling on a piece of fruit can damage the plant's underlying vascular branch or tear the skin away from the fruit stem, precipitating rapid post-harvest bacterial decay. Modern harvesting robots execute sophisticated, biologically mimicry detachment maneuvers. For example, in apple harvesting, end-effectors incorporate dual-axis rotational wrists that twist the fruit upward through a specific ninety-degree arc, snapping the stem naturally at its natural abscission layer. In strawberry and bell pepper operations, miniature high-frequency oscillating cutters or laser blades sever the pedicel cleanly, leaving a standard stem length intact without applying tension to delicate plant vines. These precise mechanical cut-and-twist maneuvers preserve plant health, ensure multi-year orchard longevity, and yield retail-ready produce that meets rigorous supermarket presentation standards.
Operational performance analysis confirms that deploying autonomous harvesting solutions drives substantial improvements across post-harvest supply chain velocity and bottom-line profitability. By integrating on-machine optical grading, robotic pickers sort harvested items immediately into specific commercial grade categories, packaging them directly into standardized transport totes inside the field. This completely bypasses the delays, double-handling, and mechanical bruising typically associated with bulk transport to centralized packing sheds. Furthermore, the precision data recorded during every individual picking event provides growers with unmatched field visibility, detailing micro-yield distributions per tree or row. This analytical feedback loop allows farm managers to optimize fertilizer disbursement, prune unproductive branches, and forecast harvest earnings with unprecedented statistical confidence, firmly establishing robotic harvesting systems as the gold standard of precision agricultural operations.
Top Trending Reports :
Electric Hub Drive Electric Propulsion System Combat Vehicle Market
Electric Lighting Equipment Market
Bub
Do?

Категории
Больше
Looking for the very best stars in EA Sports FC 26? Here we present the top 10 men and top 10 women in Ultimate Team, together with their FUT overall ratings. What “best players” means in FC 26 Ultimate Team: these are not just high-stat cards, but iconic club names whose ordinary gold cards are among the priciest items on the transfer market. Big names like Salah, Mbappé,...
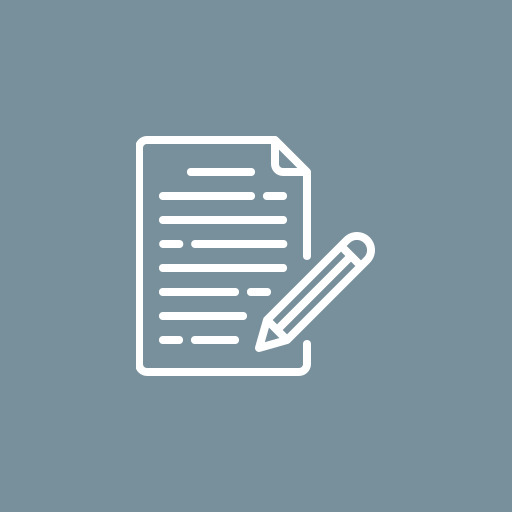
August 27, 2026 — The global zinc sulphate market is valued at USD 1.03 billion in 2026 and is projected to reach USD 1.40 billion by 2036, expanding at a 3.10% CAGR from 2026 to 2036, according to Fact.MR. The market was valued at USD 1.00 billion in 2025. Fact.MR identifies animal feed micronutrient supplementation and agricultural zinc enrichment...
Pendahuluan Bagi para penggemar bersepeda yang mencari perlengkapan tepat, waktu dan kepercayaan menjadi dua faktor paling krusial. Ketika Anda menemukan situs hao788, Anda tidak hanya mendapatkan akses ke katalog produk yang luas, melainkan juga dukungan dari brand yang memahami kebutuhan khusus para penjelajah dua roda. Artikel ini akan mengungkap cara memanfaatkan situs hao788 secara...
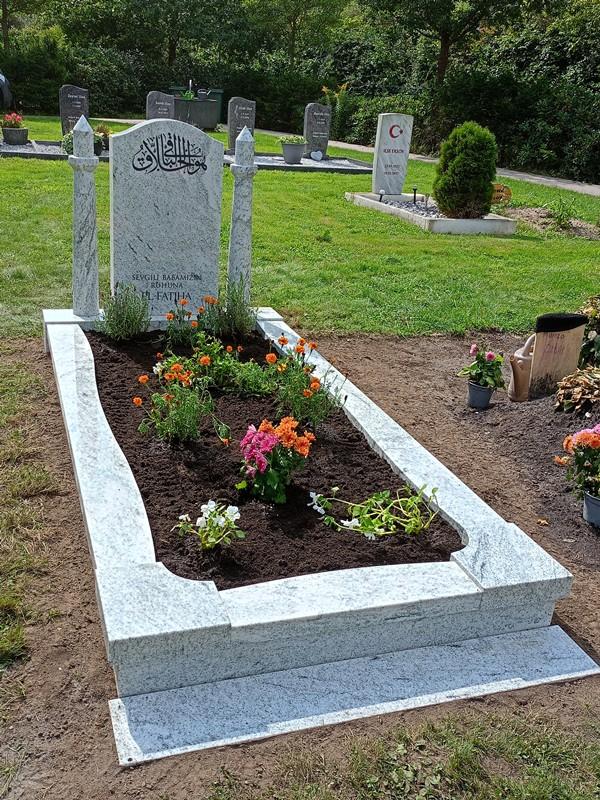
Introduction Memorial stones play an important role in preserving the memory of loved ones while reflecting cultural and religious values. In Islamic traditions, grave markers are designed with dignity, simplicity, and respect. Muslimische grabsteine are commonly used to honor the deceased while adhering to Islamic principles of modesty and remembrance. The Significance of Islamic Memorial...
Superconductors are materials that can conduct electricity without resistance, offering remarkable efficiency and performance in various industries. The potential of Superconductor applications is enormous, from power transmission to medical imaging, and from transportation to quantum computing. As Per Market Research Future, these applications are expanding rapidly, driven by technological...